ACE Robotics says its ACE-Brain-0.6 model beats GPT-6 Astra on six of eight spatial grounding tests, with a higher average score across seven public benchmarks.
By Zhou Jiaqi
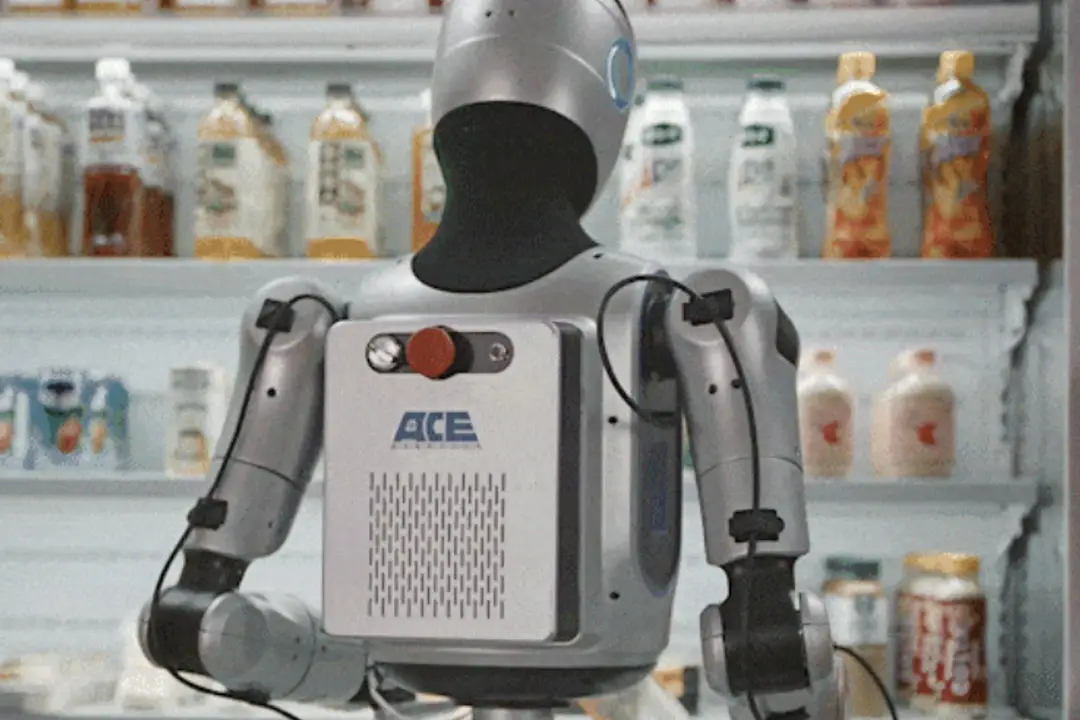
Shanghai-based ACE Robotics, known in Chinese as Daxiao Robotics, has unveiled ACE-Brain-0.6, an embodied AI model designed to improve robots’ ability to identify objects, understand spatial relationships and pinpoint where to interact with their surroundings.
The model combines perception, planning, action, evaluation and evolution in a unified cognitive loop, with a particular focus on visual-spatial grounding — connecting language instructions to specific objects, locations and interaction areas in the physical world.
The company says ACE-Brain-0.6 outperformed OpenAI’s GPT-6 Astra in six of eight grounding evaluations. Across seven public benchmarks, it scored an average of 74.53, compared with 73.68 for Astra.
Pinpointing objects and interaction points
For a robot to carry out a task, understanding an instruction is not enough. It must identify the intended object, distinguish it from similar items and determine precisely where to grasp or manipulate it.
For example, when instructed to pick up a cup, a robot must locate the correct one in a scene containing multiple similar objects, using clues such as color and position. It must then identify a suitable gripping point.
ACE-Brain-0.6 targets four capabilities: identifying objects from language descriptions, counting objects that meet specified criteria, understanding spatial relationships between objects, and locating appropriate interaction areas based on an object’s structure and function.
The last capability is particularly relevant to manipulation tasks. In a kitchen, for instance, the model needs to recognize a pan handle and identify where a robot can safely grip it.
Built on Alibaba’s Qwen3.5-9B model, ACE-Brain-0.6 uses supervised fine-tuning with spatial perception data to train the model to identify target locations, describe spatial relationships and predict interaction areas.
Six wins against GPT-6 Astra
ACE Robotics said it evaluated ACE-Brain-0.6 against GPT-6 Astra, Claude Opus 5.5 and several open-source models across eight grounding tests covering object reference, visual counting, spatial positioning, functional understanding and interaction-area prediction.
The company reports that ACE-Brain-0.6 outperformed Astra in six of the eight evaluations.
In Where2Place, the model scored 76.55, against Astra’s 71.10. In RoboSpatial, it achieved 74.82, compared with 69.55. On RoboAfford, which focuses on understanding object functions and suitable manipulation areas, ACE-Brain-0.6 scored 88.51, ahead of Astra’s 84.94.
It also led on PixMo-Count, ShareRobot and RobotGrounding, scoring 89.41, 49.70 and 94.13, respectively. Astra recorded 88.10, 46.60 and 91.10.
Across seven public benchmarks, ACE-Brain-0.6 achieved an average score of 74.53, 0.85 points higher than Astra’s 73.68, according to ACE Robotics.
The company also developed its own RobotGrounding test set to assess performance in real-world robotics scenarios. It contains 2,591 questions across 14 task categories, including object localization, small-object recognition, counting multiple instances, identifying missing targets and matching objects across different camera views.
ACE-Brain-0.6 scored 94.13 on this test, approximately 3.03 points above Astra, the company said.
ACE Robotics also compared its model with Gemini 4 Argon, Claude Opus 5.5 and models from institutions including Alibaba’s DAMO Academy and the Beijing Academy of Artificial Intelligence. The company said ACE-Brain-0.6 led in several tests of spatial localization and interaction-area understanding.
A million training samples
The company attributes the model’s gains to expanding its training data and increasing its diversity.
The team combined more than 30 families of open-source robotics datasets with proprietary first-person, or egocentric, data. The resulting collection incorporates first-person human interactions, detailed annotations of objects and their components, and three-dimensional spatial information.
For robotics videos, the team selected key frames based on gripper state and movement, then used computer vision tools including Grounding DINO and SAM 3 to locate objects and annotate relevant regions. It converted these annotations into question-and-answer data covering object identification, counting, spatial relationships and interaction locations.
Quality controls included annotation checks, balancing answers and excluding evaluation data from training. The resulting dataset comprised approximately one million training samples, including 940,000 distinct images and 2.7 million question-and-answer pairs.
During training, the team froze the visual encoder and fine-tuned the language model through supervised learning.
Controlled experiments examined how dataset size affected performance while keeping the model architecture and training method unchanged. Increasing the training set from 260,000 samples to one million raised the average score across seven public benchmarks from 69.3 to 74.5. Each doubling of the dataset increased the average score by about 2.4 points, the team found. Simply adding more data of existing types, however, produced a gain of less than one point.
The results suggest that expanding the variety of scenes, spatial relationships and supervision tasks matters alongside increasing the volume of training data.
From benchmark scores to real-world performance
Accurate spatial perception is fundamental to enabling robots to understand instructions and execute physical tasks. ACE-Brain-0.6 offers an example of how larger, more diverse spatial datasets can improve performance without increasing model size.
Whether those gains translate into greater precision, higher task-completion rates and better generalization in real-world environments remains to be demonstrated through further testing on physical robots.
Source:
Robotics Frontier